I’m a robotics researcher focused on making AI-powered robotic systems work reliably in the real world. I recently earned my Ph.D. from KAIST, where I conducted research in the Unmanned System Research Group under the supervision of Prof. David Hyunchul Shim.
My research focuses on leveraging vision-language models (VLMs) for open-ended, high-level task execution. I have experience building robust autonomous systems across diverse platforms—including mobile robots, manipulators, humanoids, and drone-tethered systems—and validating them through real-world deployments and robotics competitions.
Contact: fingb20(at)gmail(dot)com
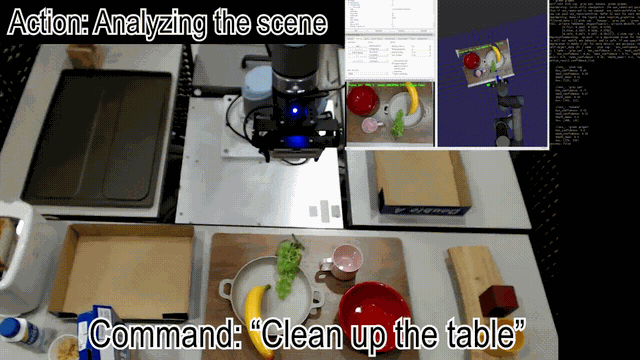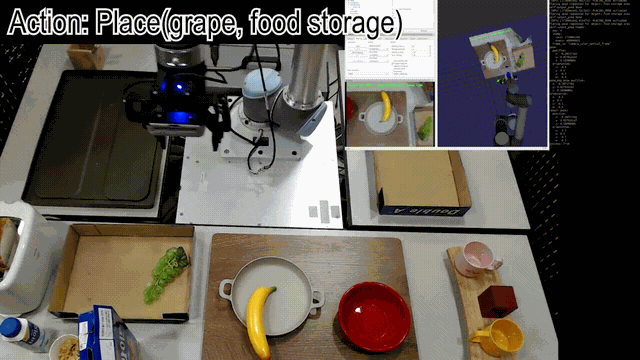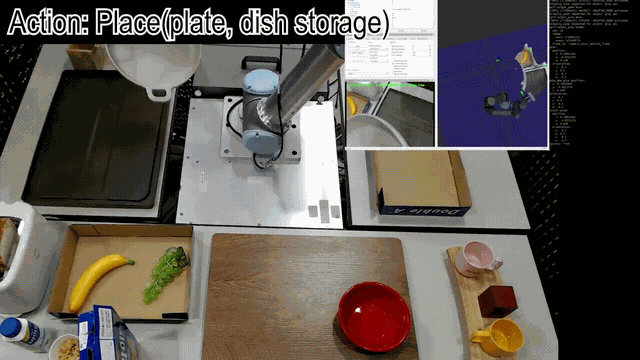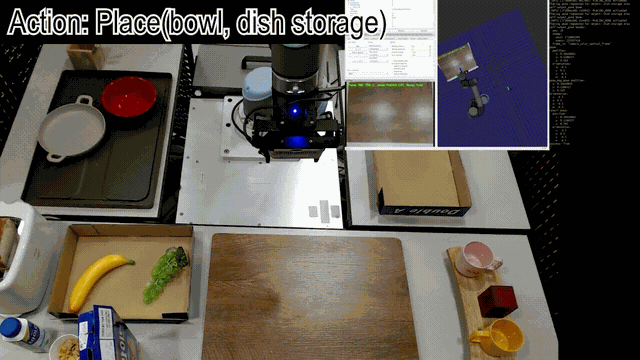
Neuro-Symbolic Agentic Planning and Open-Vocabulary Failure Recovery for Long-Horizon Robot Tasks
Low-Latency Telepresence via Gaussian Splatting With Safety-Aware Control for Mobile Manipulators
Press Coverage: [Tech Daily]
DeLTa: Demonstration and Language-Guided Novel Transparent Object Manipulation
Multi-Robot Indoor Reconnaissance and Decontamination System
Press Coverage: [The Korea Defense Daily]
Any6D: Model-free 6D Pose Estimation of Novel Objects
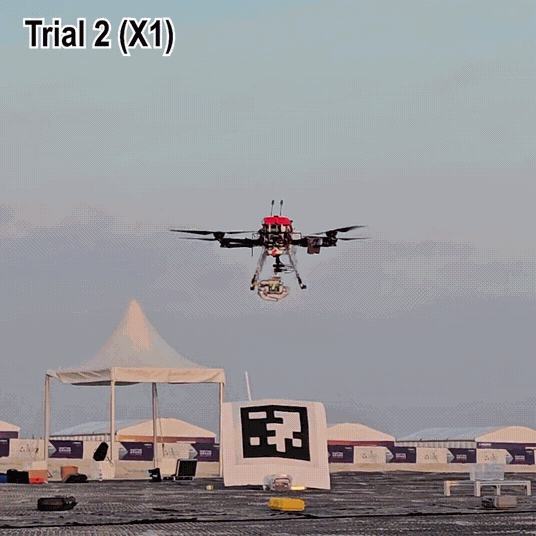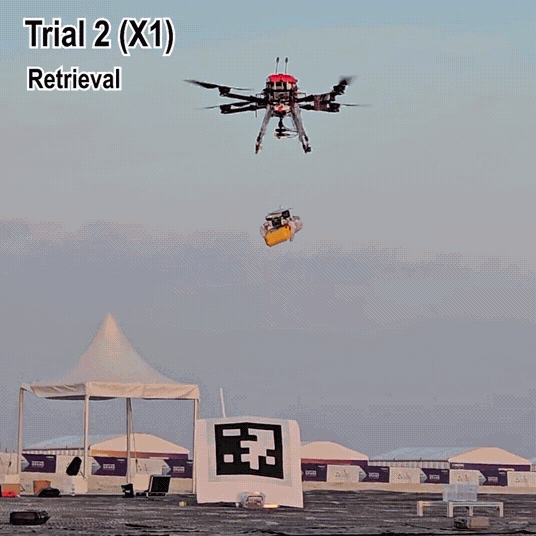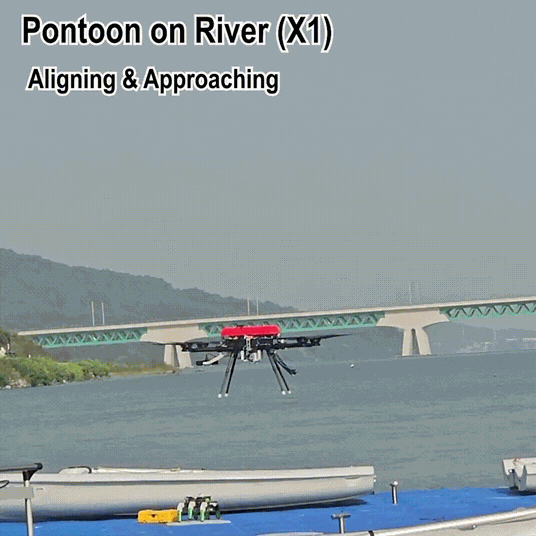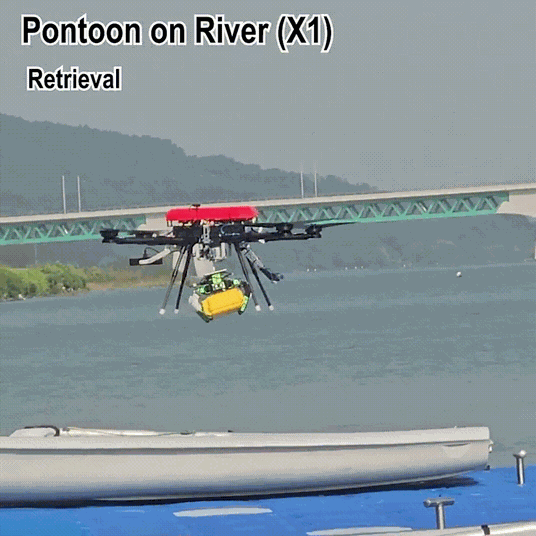
SPIBOT: A Drone-Tethered Mobile Gripper for Robust Aerial Object Retrieval in Dynamic Environments
[ICRA 2025] [KAIST Breakthroughs 2025] [Video]
Selected as KAIST Breakthroughs 2025
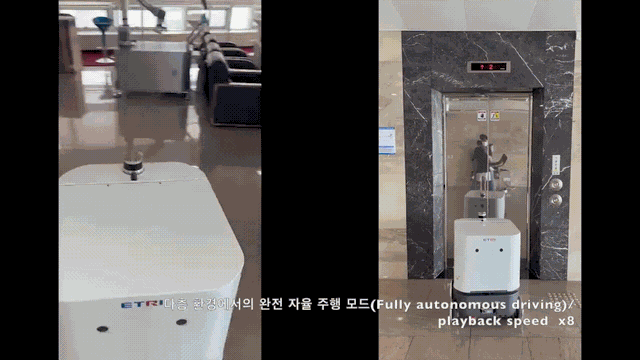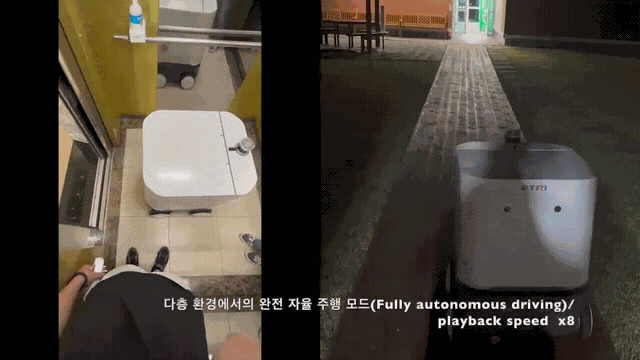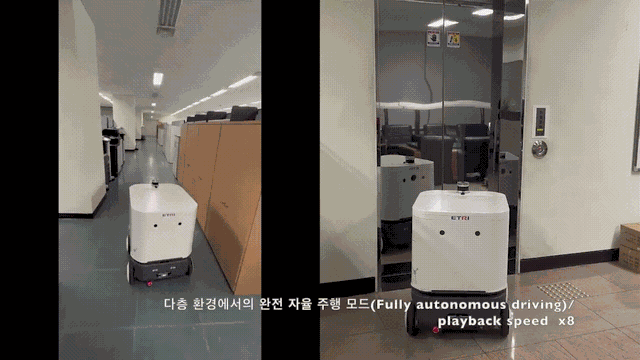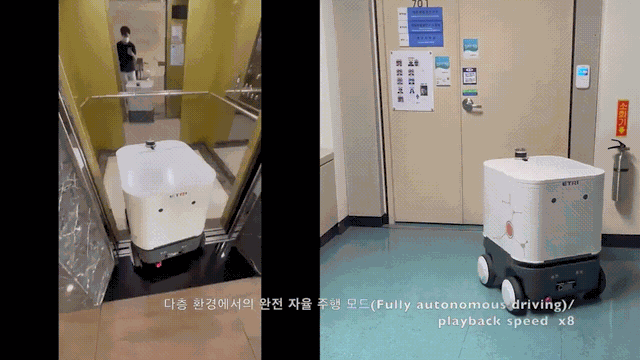
Development of an indoor delivery mobile robot for a multi-floor environment
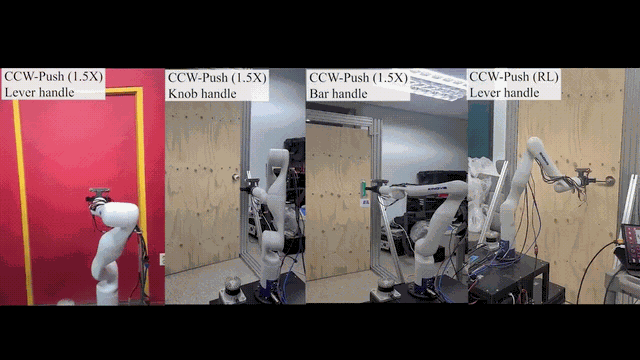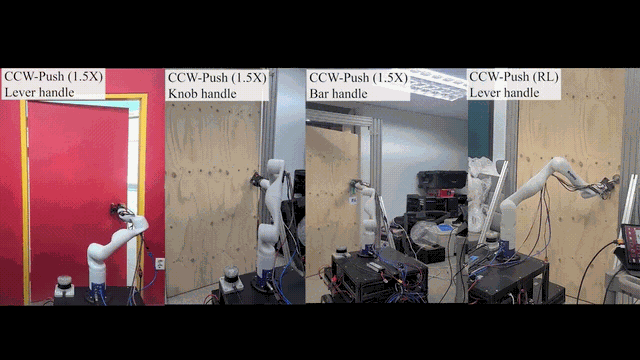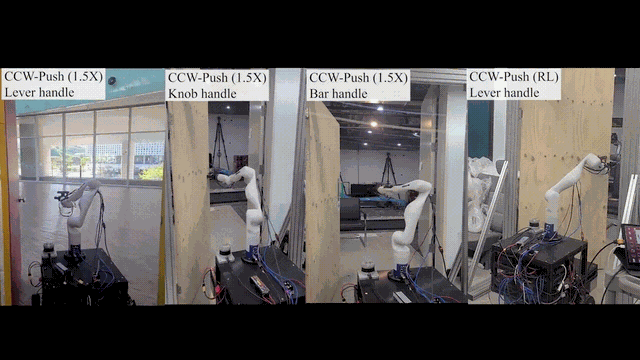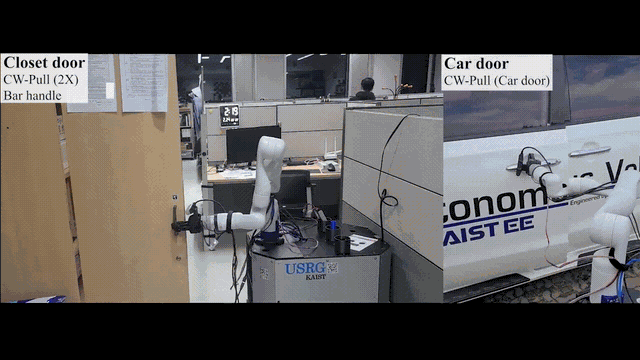
A versatile door opening system with mobile manipulator through adaptive position-force control and reinforcement learning
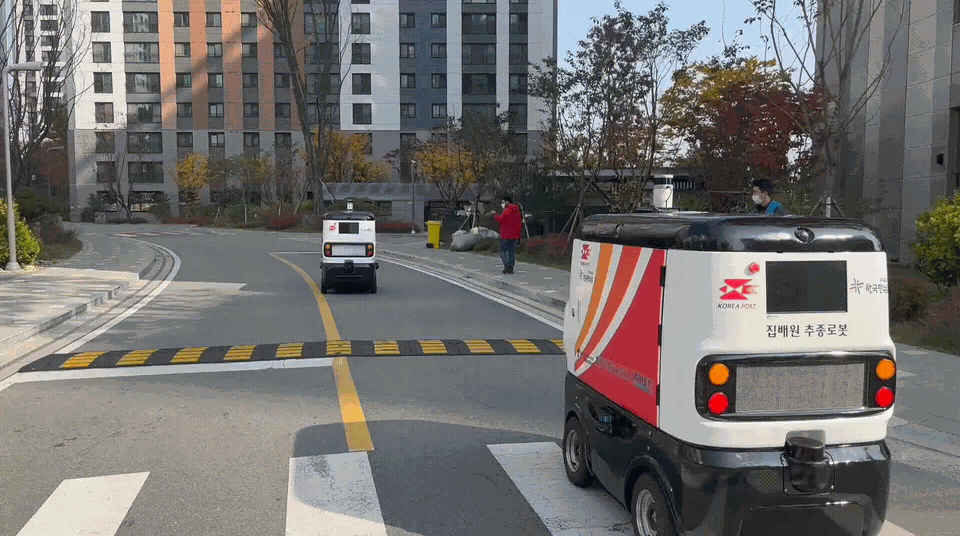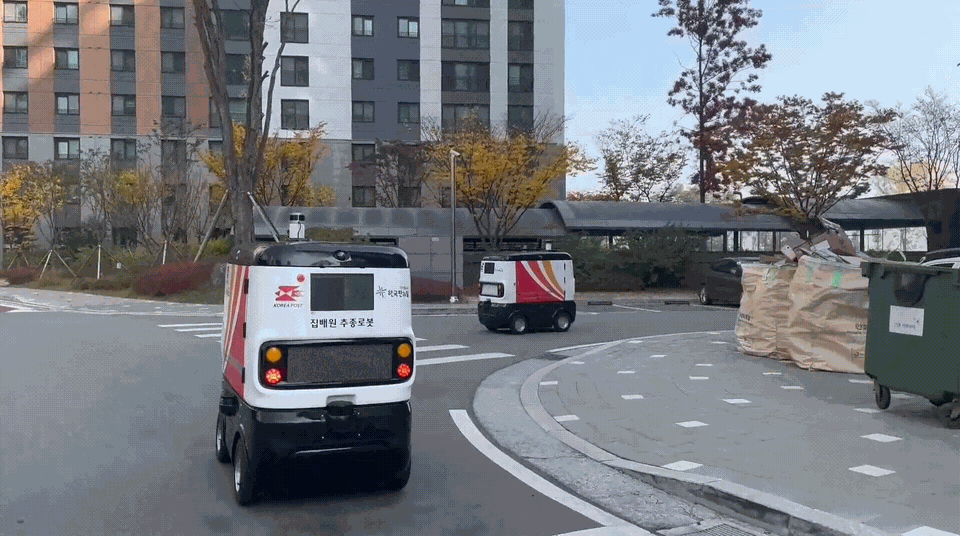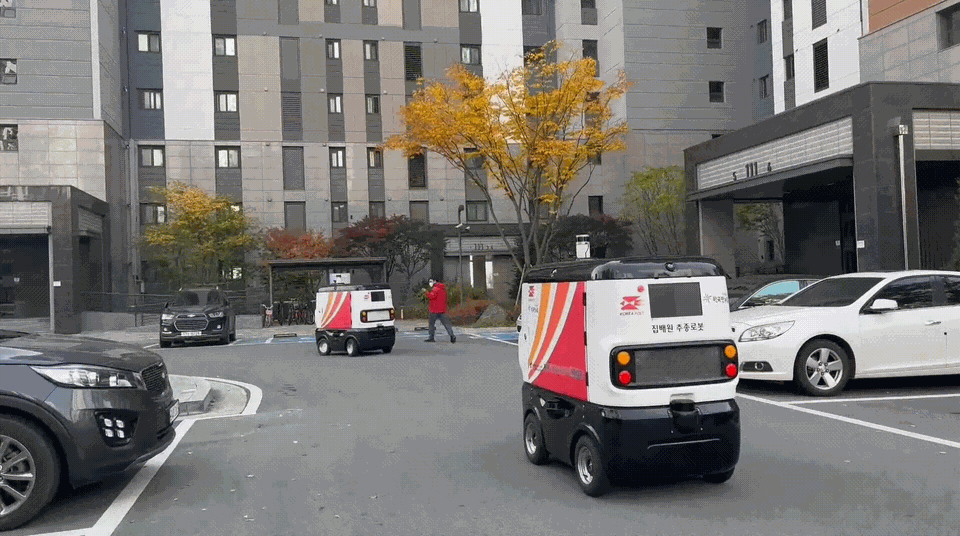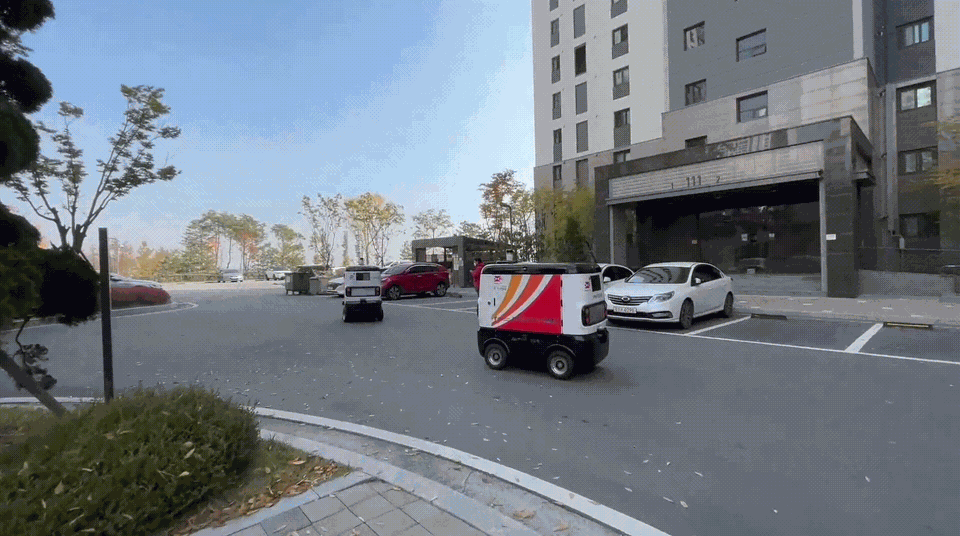
Assistive Delivery Robot Application for Real-World Postal Services
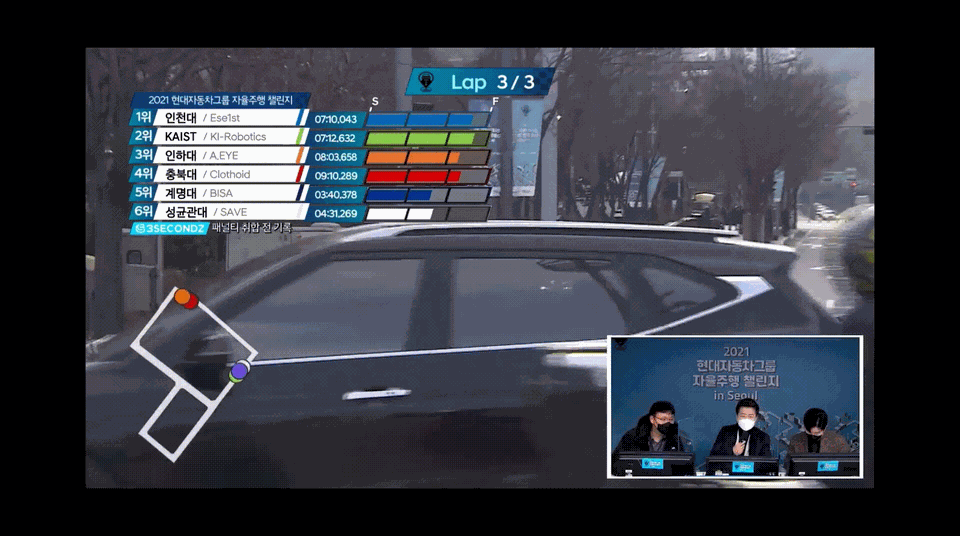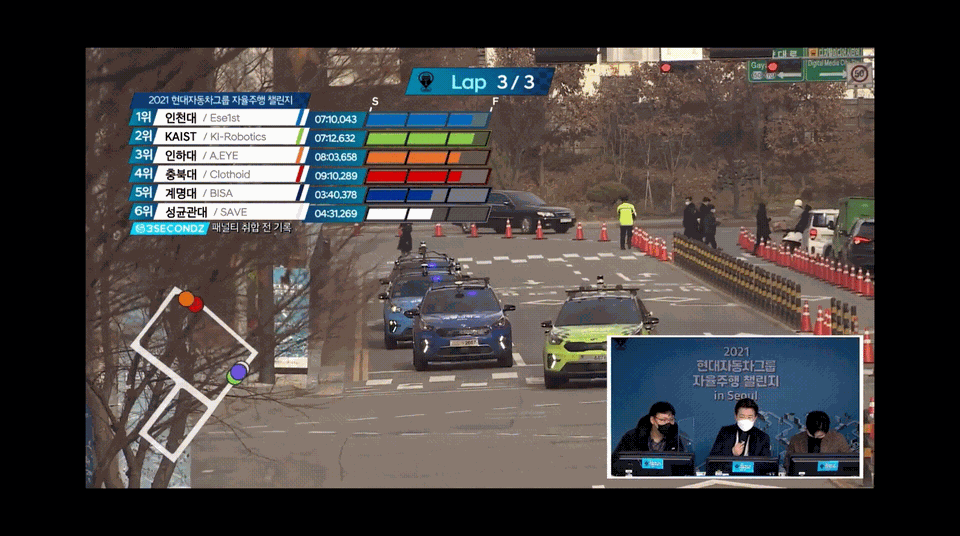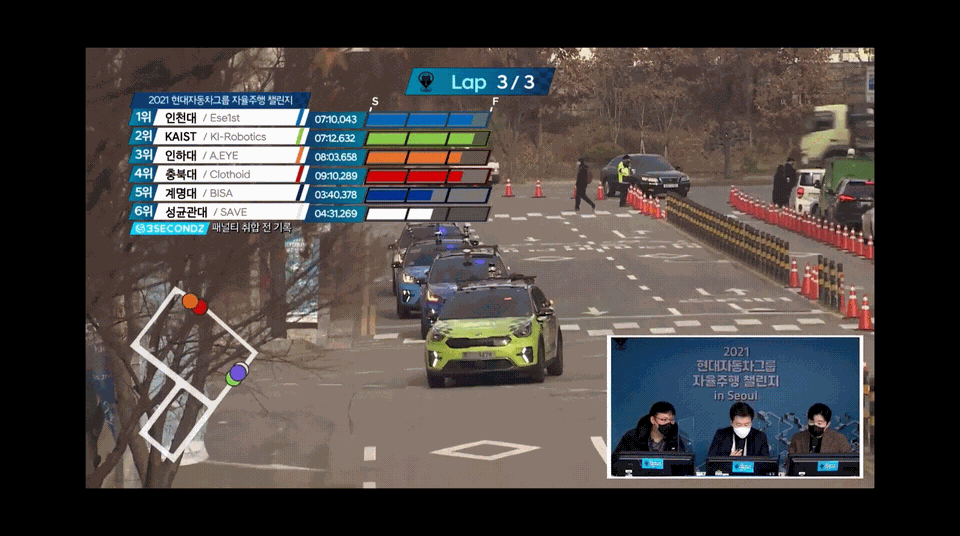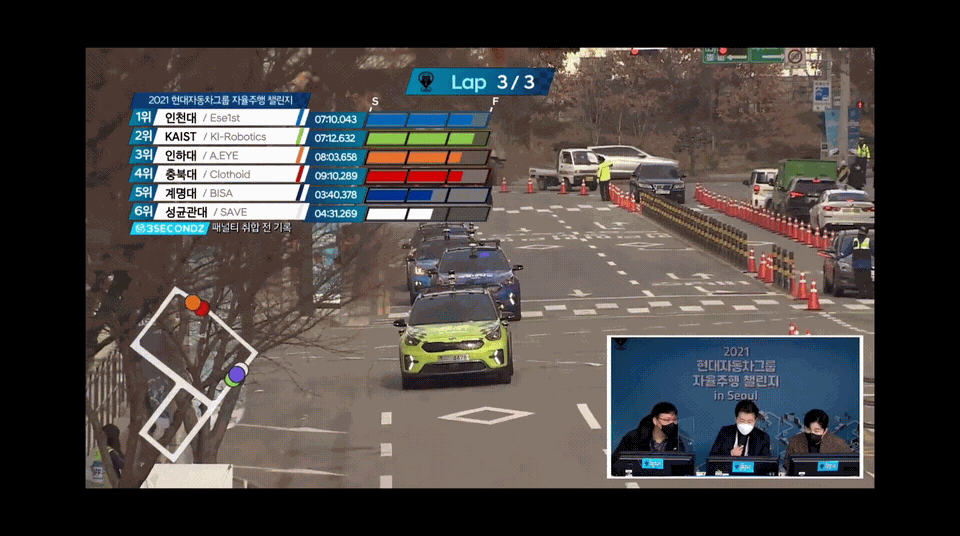
Design, Field Evaluation, and Traffic Analysis of a Competitive Autonomous Driving Model in a Congested Environment